Research Direction 02
Embodied AI & Robotics
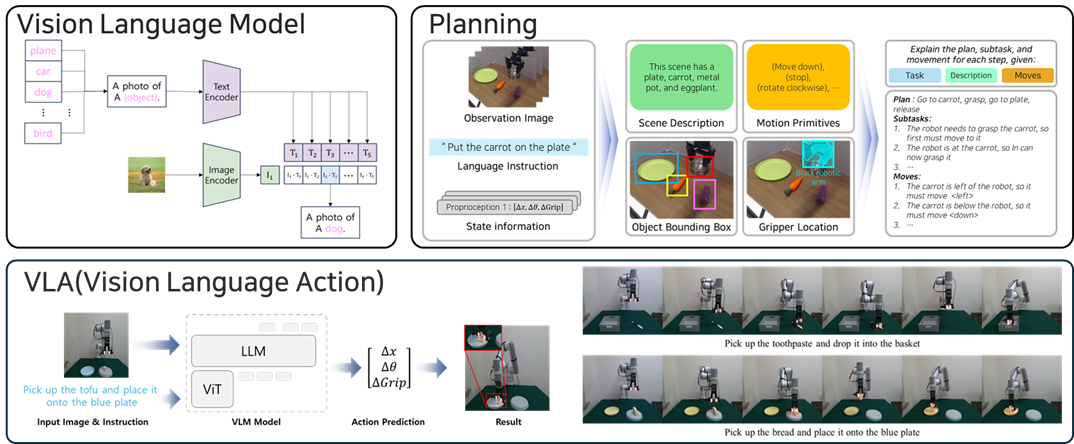
Our embodied AI research bridges perception and action through planning, control, and interactive decision-making in physical environments. We investigate data-efficient learning methods for robotic manipulation and embodied interaction, focusing on how agents can acquire skills from limited data and adapt to new situations. Our goal is to build robust embodied agents that tightly integrate perception, reasoning, and action, enabling reliable operation in complex and unstructured real-world settings.
Research Topics
Vision-Language-Action (VLA)
Embodied Agents
Robotic Manipulation
Planning & Control
Data-Efficient Learning
Interactive Decision-Making